Paper I — Q2
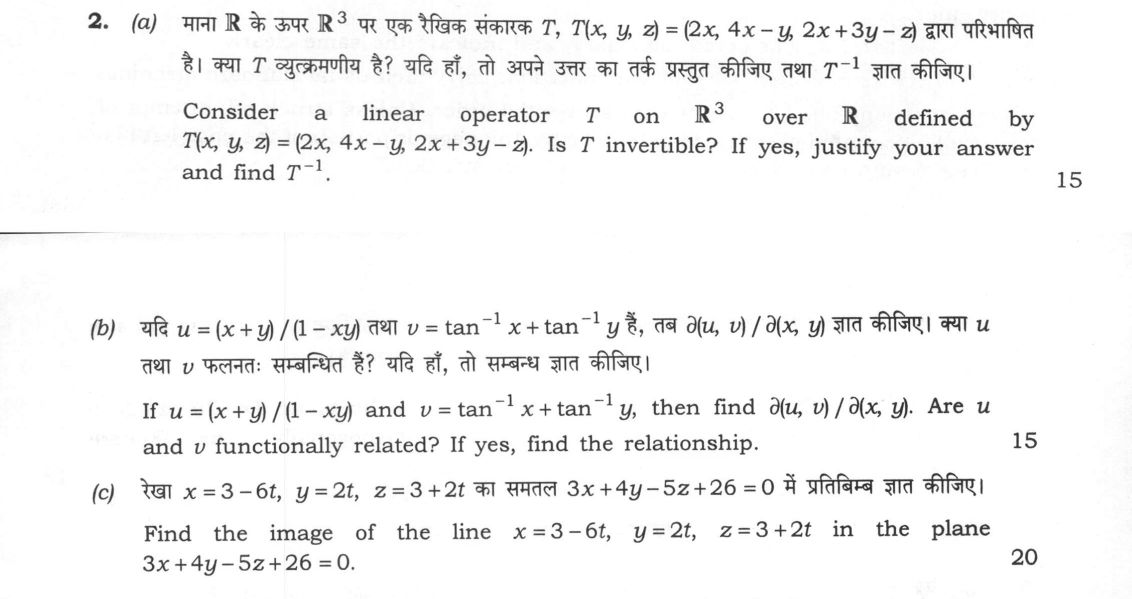
(a) Consider a linear operator T on R³ over R defined by T(x, y, z) = (2x, 4x – y, 2x + 3y – z). Is T invertible? If yes, justify…
Consider a linear operator T on R³ over R defined by T(x, y, z) = (2x, 4x – y, 2x + 3y – z). Is T invertible? If yes, justify your answer and find T⁻¹. 15 marks
If u = (x+y)/(1-xy) and v = tan⁻¹x + tan⁻¹y, then find ∂(u, v)/∂(x, y). Are u and v functionally related? If yes, find the relationship. 15 marks
Find the image of the line x = 3-6t, y = 2t, z = 3+2t in the plane 3x+4y-5z+26 = 0. 20 marks
हिंदी में प्रश्न पढ़ें
माना R के ऊपर R³ पर एक रैखिक संकारक T, T(x, y, z) = (2x, 4x – y, 2x + 3y – z) द्वारा परिभाषित है। क्या T व्युत्क्रमणीय है? यदि हाँ, तो अपने उत्तर का तर्क प्रस्तुत कीजिए तथा T⁻¹ ज्ञात कीजिए। (15 अंक)
यदि u = (x+y)/(1-xy) तथा v = tan⁻¹x + tan⁻¹y है, तब ∂(u, v)/∂(x, y) ज्ञात कीजिए। क्या u तथा v फलनतः सम्बन्धित हैं? यदि हाँ, तो सम्बन्ध ज्ञात कीजिए। (15 अंक)
रेखा x = 3-6t, y = 2t, z = 3+2t का समतल 3x+4y-5z+26 = 0 में प्रतिबिम्ब ज्ञात कीजिए। (20 अंक)
Model answer
Drafted with AI by UPSC Answer Check against this question's marking rubric, to the expected length. UPSC does not publish answers for Mains — this is one way to score well, not an official key. How we build rubrics and answers.
(a) T(x, y, z) = (2x, 4x − y, 2x + 3y − z). Its standard matrix is
A = [[2, 0, 0], [4, −1, 0], [2, 3, −1]].
Using the determinant of a lower-triangular matrix,
det A = 2 × (−1) × (−1) = 2 ≠ 0.
Hence T is invertible.
Let T(x, y, z) = (X, Y, Z). Then
X = 2x ⇒ x = X/2.
Y = 4x − y ⇒ y = 4x − Y = 2X − Y.
Z = 2x + 3y − z ⇒ z = 2x + 3y − Z.
Substituting x and y:
z = X + 3(2X − Y) − Z = 7X − 3Y − Z.
Therefore
T⁻¹(X, Y, Z) = (X/2, 2X − Y, 7X − 3Y − Z).
Final answer (a): T is invertible since det A = 2 ≠ 0, and T⁻¹(X, Y, Z) = (X/2, 2X − Y, 7X − 3Y − Z).
(b) Given
u = (x + y)/(1 − xy), v = tan⁻¹ x + tan⁻¹ y.
By the quotient rule,
∂u/∂x = [(1)(1 − xy) − (x + y)(−y)]/(1 − xy)² = (1 + y²)/(1 − xy)².
Similarly,
∂u/∂y = [(1)(1 − xy) − (x + y)(−x)]/(1 − xy)² = (1 + x²)/(1 − xy)².
Also,
∂v/∂x = 1/(1 + x²), ∂v/∂y = 1/(1 + y²).
The Jacobian is
∂(u, v)/∂(x, y) = determinant of [[∂u/∂x, ∂u/∂y], [∂v/∂x, ∂v/∂y]]
= (∂u/∂x)(∂v/∂y) − (∂u/∂y)(∂v/∂x)
= [(1 + y²)/(1 − xy)²]·[1/(1 + y²)] − [(1 + x²)/(1 − xy)²]·[1/(1 + x²)]
= 1/(1 − xy)² − 1/(1 − xy)²
= 0.
Since the Jacobian vanishes identically wherever the derivatives exist, u and v are functionally related.
Now let x = tan α and y = tan β. Then
v = α + β,
and
u = (tan α + tan β)/(1 − tan α tan β) = tan(α + β) = tan v.
Thus the functional relation is
u = tan v, provided 1 − xy ≠ 0.
Equivalently, on branches,
v = tan⁻¹ u + kπ, k ∈ Z.
Final answer (b): ∂(u, v)/∂(x, y) = 0. u and v are functionally related, and the relation is u = tan v.
(c) The ‘image’ of the line in the plane is taken here in the standard sense of its mirror image (reflection). The given line is
r(t) = (3 − 6t, 2t, 3 + 2t),
so its direction vector is
d = (−6, 2, 2).
The plane is
3x + 4y − 5z + 26 = 0,
so its normal vector is
n = (3, 4, −5).
For reflection in the plane, the component of d along n reverses sign. First find the intersection of the line with the plane. Substitute the line into the plane:
3(3 − 6t) + 4(2t) − 5(3 + 2t) + 26 = 0
= 9 − 18t + 8t − 15 − 10t + 26
= 20 − 20t.
Thus t = 1. The point of intersection is
A = (3 − 6, 2, 3 + 2) = (−3, 2, 5).
Now reflect the direction vector d across the plane. Use
d′ = d − [2(d·n)/(n·n)]n.
Compute
d·n = (−6)(3) + (2)(4) + (2)(−5) = −18 + 8 − 10 = −20,
n·n = 3² + 4² + (−5)² = 9 + 16 + 25 = 50.
Therefore,
d′ = (−6, 2, 2) − [2(−20)/50](3, 4, −5)
= (−6, 2, 2) + (4/5)(3, 4, −5)
= (−6 + 12/5, 2 + 16/5, 2 − 4)
= (−18/5, 26/5, −2).
This is proportional to (−9, 13, −5).
Hence the reflected line passes through A = (−3, 2, 5) and has direction (−9, 13, −5).
Its parametric form is
x = −3 − 9s, y = 2 + 13s, z = 5 − 5s, s ∈ R.
Its Cartesian form is
(x + 3)/(−9) = (y − 2)/13 = (z − 5)/(−5).
Equivalently,
(x + 3)/9 = (y − 2)/(−13) = (z − 5)/5.
Check: the point (3, 0, 3) of the given line reflects to (3/5, −16/5, 7), which lies on this line (s = −0.4).
If 'image' is read instead as the orthogonal projection on the plane, the direction is d − [(d·n)/(n·n)]n ∝ (−4, 3, 0), giving (x + 3)/(−4) = (y − 2)/3, z = 5.
Final answer (c): The image line is
x = −3 − 9s, y = 2 + 13s, z = 5 − 5s, s ∈ R,
or in Cartesian form,
(x + 3)/9 = (y − 2)/(−13) = (z − 5)/5.
How this answer will be evaluated
What earns full marks: Complete working with all steps, correct results, and verification.
Evaluation rubric
Each sub-part is marked on its own, against the marks and word limit printed on the paper.
- (a) Is T(x,y,z) = (2x, 4x − y, 2x + 3y − z) invertible? Find T⁻¹. 15 marks
justify— claim → 3-4 reasons → evidence → conclusion
Must cover
- Matrix of T and det = 2 ≠ 0 (or kernel trivial)
- Conclusion: T invertible
- Solving for x, y, z
- T⁻¹(X,Y,Z) = (X/2, 2X − Y, 7X − 3Y − Z)
Loses marks
- Arithmetic error in z-component
Earns more
- Verification T∘T⁻¹ = I
Extra mark
- Inverse matrix displayed
- (b) Jacobian ∂(u,v)/∂(x,y); functional relation between u and v. 15 marks
calculate— given → formula → substitution → result with units → interpretation
Must cover
- Partial derivatives of u and v
- Jacobian = 0
- Inference of functional dependence
- Relation u = tan v (x = tan α, y = tan β)
Loses marks
- Jacobian non-zero due to algebra error
- Relation stated without derivation
Earns more
- Domain condition 1 − xy ≠ 0
Extra mark
- Branch remark v = tan⁻¹u + kπ
- (c) Image (reflection) of the line x = 3 − 6t, y = 2t, z = 3 + 2t in the plane 3x + 4y − 5z + 26 = 0. 20 marks
calculate— given → formula → substitution → result with units → interpretation
Must cover
- Intersection point (−3, 2, 5) at t = 1
- Reflection of a second point, e.g., (3,0,3) → (3/5, −16/5, 7), or reflection of direction vector
- Direction of image (−9, 13, −5)
- Equation (x + 3)/9 = (y − 2)/(−13) = (z − 5)/5
Loses marks
- Wrong intersection point
- Using the normal incorrectly in reflection formula
Earns more
- Projection alternative (x + 3)/(−4) = (y − 2)/3, z = 5 if 'image' read as projection, clearly stated
Extra mark
- Verification that the image point lies on the line
What "Solve" is asking you to do
Choose the method, then carry it through to a final answer. Identifying what kind of problem this is and why that method applies is the first thing marked; a correct figure arrived at invisibly earns almost nothing.
Structure that answers it
Given data and what is required → method chosen, with the reason it applies → set-up (equation, circuit, free body, trial balance) → working, step by step → answer with units and any condition of validity
Where marks are lost
Doing the middle steps mentally and writing only the result. In mathematics papers, a further loss comes from giving a decimal where the exact value in surds or fractions was wanted, or from skipping the justification a part explicitly asks for.
Practice this exact question
Write your answer and it is marked point by point against the model answer above — what you covered, what you missed, what you got wrong.
Evaluate my answer →More from Mathematics 2024 Paper I
- Q1 (a) Let H be a subspace of R⁴ spanned by the vectors v₁ = (1, –2, 5, –3), v₂ = (2, 3, 1,…
- Q2 (a) Consider a linear operator T on R³ over R defined by T(x, y, z) = (2x, 4x – y, 2x + 3…
- Q3 (a) Let V = M₂ₓ₂(ℝ) denote a vector space over the field of real numbers. Find the matrix…
- Q4 (a) Let A = 3 & 2 & 4 2 & 0 & 2 4 & 2 & 3 be a 3×3 matrix. Find the eigenvalues and the c…
- Q5 (a) Find the orthogonal trajectories of the family of curves r = c(sec θ + tan θ), where…